BREVETTI+ Valorization of the patent “Payload for fruit harvesting and pruning in row crops, particularly vineyards”
- Call title: BREVETTI+ The incentive for the economic valorization of patents
- Project title: Valorization of the patent “Payload for fruit harvesting and pruning in row crops, particularly vineyards”
- Patent No: 102024000000639
- Project protocol: BRE0002322
- CUP: C89J24001920008
- Investment cost: € 148,960.00
- Granted awarded: € 119,168.00
PROJECT FUNDED BY INVITALIA
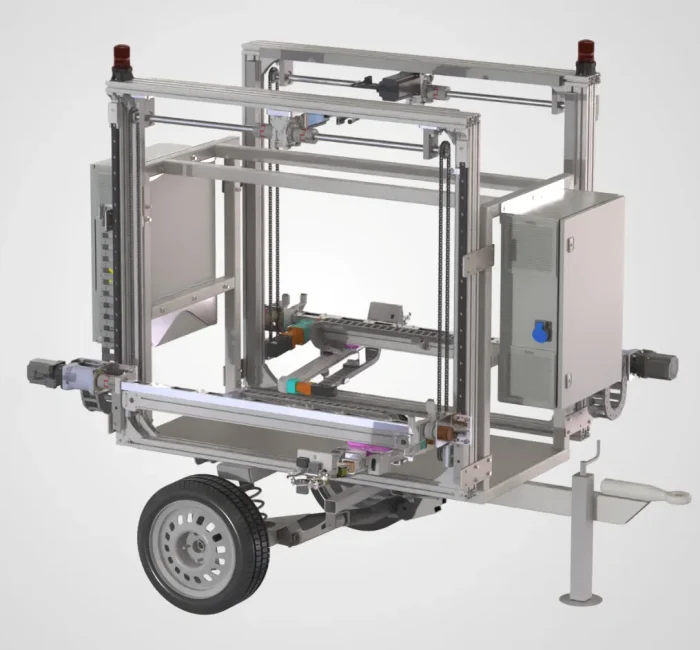
Project BRE0002322 was developed with the aim of valorizing the patent “Payload for fruit harvesting and pruning in row crops, particularly vineyards” through a progressive process of technical analysis, design and engineering, accompanied by the definition of a communication strategy and channel management approach consistent with the maturation of the technology.
Technological objectives
verify the technical and functional feasibility of the robotic payload for pruning and harvesting;
define a modular architecture that can be integrated on tractors or agricultural rovers;
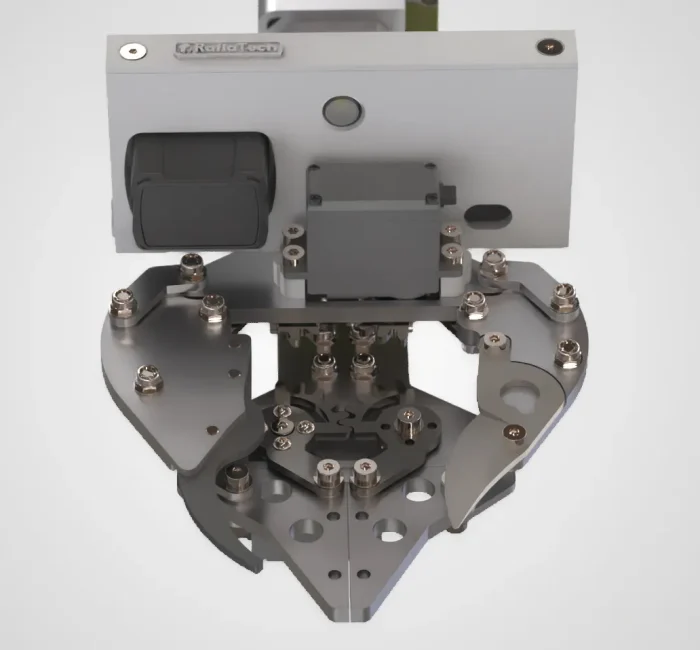
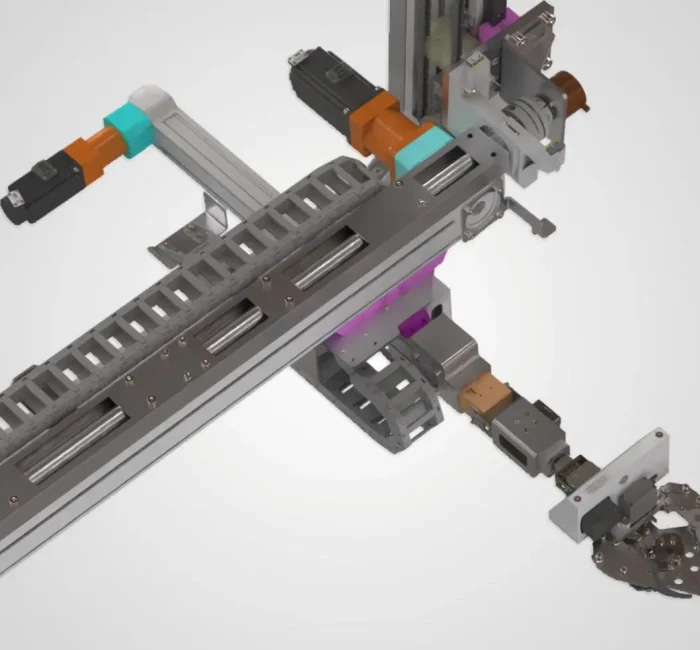
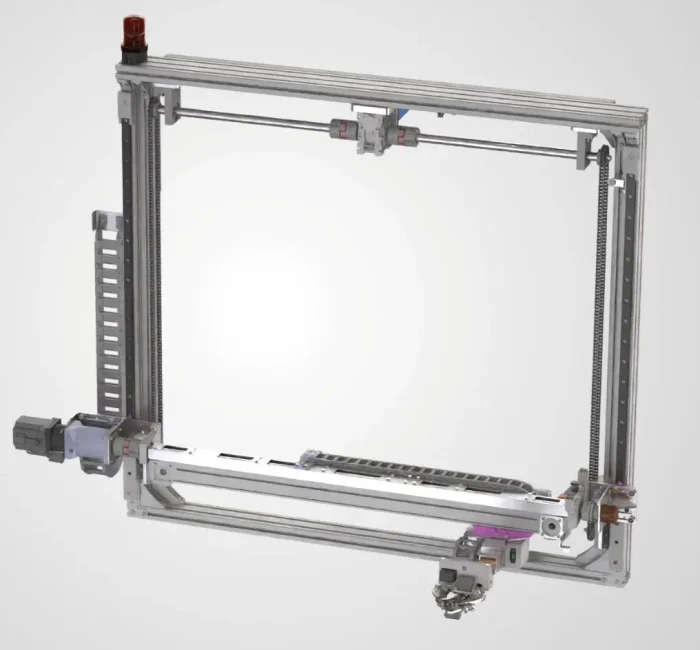
develop the motion, vision, control, sensing and end-effector subsystems;
build a first integrated and functional prototype unit;
validate in the laboratory the main operating sequences for identification, gripping, cutting, transfer and deposition;
Project activities
Technical-functional feasibility study, including the definition of requirements, specifications and system architecture.
Mechanical design of the modular structure, motion systems and end-effectors for pruning and harvesting.
Electronic and control system design, including power supply, sensors, vision, communications and safety systems.
Integration and prototyping of the mechanical, electrical and software subsystems into a first complete unit.
Laboratory functional testing of the main pruning and harvesting operating sequences.
Definition of the communication and valorization strategy, including identification of targets, channels, KPIs and roadmap.
Innovation
Automation of pruning and harvesting through a single robotic payload capable of managing target identification, motion, cutting, gripping and deposition.
Modular architecture that can be integrated on tractors or rovers, separating vehicle navigation from the agronomic operations performed locally by the payload.
Common mechatronic platform for both operations, with a multi-axis motion system and a shared, reconfigurable end-effector.
Integration of advanced vision and control systems, including stereo vision installed on the manipulator and coordinated management of the subsystems.
Development of a first integrated and verified prototype unit, and preparation for subsequent validation in a relevant vineyard environment.
Expected impacts
Economic
Reduction in the operating costs of pruning and harvesting activities, increased productivity, and creation of the conditions for future industrialization and commercialization of the solution.
Social
Support for operators in the most repetitive and demanding activities, with potential improvement in working conditions and reduced dependence on scarce seasonal labor.
Technological
Development of a modular robotic platform integrating motion, vision, control and end-effector systems, and preparation for subsequent vineyard validation phases.
Environmental
Greater precision and selectivity in operations on the plant, with a potential reduction in waste compared with traditional mechanical solutions.
Conclusion
The project made it possible to transform the initial patented concept into a concretely designed, integrated and verified robotic solution, demonstrating the technical feasibility of the system for pruning and harvesting operations in the wine-growing sector and strengthening the technological value of the patent, thereby creating the basis for future market introduction.